
The 3rd International Conference on Advanced Robotics, Control, and Artificial Intelligence (ARCAI 2026)
November 22-26, 2026, Singapore
Keynote Speeches

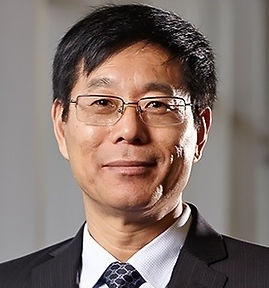
Professor Changyun Wen, IEEE Fellow, EiC of IEEE TCPS
Nanyang Technological University
Talk: Decentralized Prescribed-Time Control for Interconnected Systems
Abstract:
A significant challenge of decentralized control is how to ensure global stability in large-scale interconnected systems by local controllers that employ only local information. Since earlier 1980s, decentralized adaptive control has motivated continued exploration and research of many researchers. However, in the presence of uncertainties and strong interactions, the proposed schemes in this area have generally been limited to achieving stability only over an infinite time horizon, with the elimination of steady-state errors posing a particular challenge. Decades of attempts to enhance the convergence rate of decentralized control schemes have made little progress.
Recently, a methodology termed prescribed-time control has emerged, demonstrating advantages in achieving accelerated convergence and superior disturbance rejection. The core innovation lies in an unbounded time-varying feedback gain, which enables precise control without prior disturbance knowledge and, crucially, allows for a convergence time that is pre-assignable by the designer. Building on this principle, we recently achieved a key breakthrough: not only developed a decentralized prescribed-time control framework for strongly interconnected systems but also solved the long-standing problem of achieving precise control in such systems under disturbances. The details of the proposed approach and established results will be covered in this talk.
Bio:
Changyun Wen received his B.Eng from Xi’an Jiaotong University, China in July 1983 and Ph.D from the University of Newcastle, Australia in Feb 1990. From August 1989 to August 1991, he was a Research Associate and then Postdoctoral Fellow at the University of Adelaide, Australia. Since August 1991, He has been with Technological University as a lecturer (from 1991), senior lecturer (from 1995), associate professor (from 1999) and full professor (from 2008).
He is a Fellow of IEEE, was a Member of the IEEE Fellow Committee from Jan 2011 to Dec 2013 and a Distinguished Lecturer of IEEE Control Systems Society from Feb 2010 to Feb 2013. He is also a Fellow of the Academy of Engineering, Singapore.
Prof. Wen is the Editor-in-Chief of IEEE Transactions on Industrial Cyber-Physical Systems, a co-Editor-in-Chief of IEEE Transactions on Industrial Electronics (from July 2020), an Associate Editor of Automatica (from Feb 2006) and the Executive Editor-in-Chief of Journal of Control and Decision. He also served as an Associate Editor of IEEE Transactions on Automatic Control from Jan 2000 to Dec 2002, IEEE Transactions on Industrial Electronics (from May 2013 to Jan 2020) and IEEE Control Systems Magazine from 2009 to 2019, respectively. He has been actively involved in organizing international conferences playing the roles of General Chair, Technical Program Committee Chair, Program Committee Member, General Advisor, Publicity Chair and so on. He was the recipient of several awards, including the IES Prestigious Engineering Achievement Award from the Institution of Engineers, Singapore in 2005, Best Paper Award of IEEE Transactions on Industrial Electronics in 2017, Clarivate Analytics Highly Cited Researcher in the field of Engineering yearly from 2020 to 2025, Stanford/Elsevier Top 2% Scientist Worldwide yearly from 2021 to 2025. His main research activities are in the areas of control systems with applications to cyber-physical systems, smart grids and so on.

Professor Abbas Jamalipour, Fellow IEEE, Fellow IEAust, Fellow IEICE, Fellow AIIA, Fellow AAIS
The University of Sydney, Australia
Talk: Agentic Artificial Intelligence in Satellite-Aerial-Terrestrial Integrated Networks
Abstract:
The rapid emergence of the low-altitude economy is transforming the way people, goods, and services move through the air, creating new opportunities in autonomous logistics, urban air mobility, precision agriculture, environmental monitoring, and beyond. Enabled by advances in satellite communications, uncrewed aerial vehicles, and intelligent aerial platforms, this new ecosystem demands seamless, reliable, and ubiquitous connectivity across highly dynamic low-altitude environments where conventional terrestrial networks alone are often insufficient. As a result, the integration of multi-orbit satellite systems, aerial platforms, and terrestrial infrastructure is becoming a foundational pillar of future communications, aligning closely with the 6G vision of space-air-ground integrated networks. At the same time, managing such heterogeneous, large-scale, and mission-critical infrastructure presents unprecedented challenges in network intelligence, adaptability, and resilience. This talk explores how agentic artificial intelligence, powered by generative AI and large language models, can enable autonomous agents that perceive, reason, and act to optimize network operations, enhance service reliability, and support emerging low-altitude applications. Bringing together advances in communications and AI, the talk will highlight key challenges, recent innovations, and future research directions that will shape the intelligent, connected, and autonomous low-altitude economy of the future.
Bio:
Abbas Jamalipour received the Ph.D. degree in Electrical Engineering from Nagoya University, Nagoya, Japan in 1996. He is the Professor of Ubiquitous Mobile Networking at the University of Sydney. He has authored nine technical books, eleven book chapters, over 650 technical papers, and five patents, all in wireless communications and networking. Prof. Jamalipour is the recipient of several prestigious awards such as the 2025 Neville Thiele Eminence Award from Engineers Australia, IEEE ComSoc Harold Sobol Award, the IEEE ComSoc Best Tutorial Paper Award, as well as over fifteen Best Paper Awards. He has held positions of President, Executive Vice-President, elected member of the Board of Governors of IEEE Vehicular Technology Society, and the Editor-in-Chief of IEEE TRANSACTIONS ON VEHICULAR TECHNOLOGY and VTS Mobile World. He was the Editor-in-Chief IEEE WIRELESS COMMUNICATIONS, the Vice President-Conferences, and a member of Board of Governors of the IEEE Communications Society. Currently he serves as the IEEE ComSoc Vice President-MGA and the IEEE VTS Vice President-Publications. He is a Fellow of the IEEE, the Institute of Electrical, Information, and Communication Engineers (IEICE), the Institution of Engineers Australia (IEAust), the International Artificial Intelligence Industry Alliance (AIIA), the International Academy of Artificial Intelligence Sciences, and the Visiting Fellow of the UK Royal Academy of Engineering.
Professor Qing-Long Han, FIEEE, FIFAC, FACA, HonFIEAust, FCAA
Swinburne University of Technology, Australia
Talk: Driving the Future of Transport: Communication-Efficient and Cyber-Secure Coordination Control
Abstract:
The evolution of intelligent transportation systems hinges on the seamless integration of connected and automated technologies, yet challenges in communication efficiency and cybersecurity remain critical barriers to their widespread adoption.
This Keynote Address explores innovative solutions to drive the future of transport, focusing on two pivotal research domains: communication-efficient coordination control and cyber-secure coordination control for connected automated vehicle (CAV) platoons and connected railway systems. The Keynote Address begins with a concise overview of connected automated transport, followed by an in-depth exploration of key design and implementation challenges in such systems. Novel event-triggered coordination control strategies that dynamically schedule vehicle-to-vehicle and train-to-train communication are then presented, enhancing communication resource efficiency by reducing unnecessary data exchanges while preserving precious bandwidth resources. These mechanisms adapt to real-time network conditions, ensuring efficient platooning for CAVs and virtual coupling for railways. Additionally, resilient and secure control techniques designed to withstand, detect, and mitigate cyber threats are discussed, safeguarding the integrity of networked transportation systems against various cyber-attacks such as denial-of-service and data falsification and replaying. Drawing on theoretical advancements, simulation results, and practical implications, this speech highlights how these advancements pave the way for a safer, more efficient, and resilient transportation ecosystem, addressing the pressing demands of future mobility.
Bio:
Professor Han is currently Pro Vice-Chancellor (Research Quality) and a Distinguished Professor at Swinburne University of Technology, Melbourne, Australia. He held various academic and management positions at Griffith University, Central Queensland University, Australia, Southern Illinois University Edwardsville, USA, and École Nationale Supérieure d’Ingénieurs de Poitiers, France. His research interests include networked control systems, multi-agent systems, time-delay systems, smart grids, unmanned surface vehicles, and neural networks.
Professor Han was awarded the 2024 IEEE Dr.-Ing. Eugene Mittelmann Achievement Award (Highest Achievement Award in Industrial Electronics), the 2024 Chinese Association of Automation (CAA) Science and Technology Achievement Award (the CAA’s Highest Achievement Award in Automation, Information and Intelligent Science), the 2021 Norbert Wiener Award (the Highest Achievement Award in Systems Science and Engineering, and Cybernetics), and the 2021 M. A. Sargent Medal (the Highest Achievement Award of the Electrical College Board of Engineers Australia). He was the recipient of the Journal of Systems Science and Complexity Best Paper Award in 2023, the IEEE Systems, Man, and Cybernetics Society Andrew P. Sage Best Transactions Paper Award in 2019, 2020, and 2022, respectively, the IEEE/CAA Journal of Automatica Sinica Norbert Wiener Review Award in 2020, the IEEE Transactions on Industrial Informatics Outstanding Paper Award in 2020, and the IET Control Theory and Applications Premium (Best Paper) Award in 2020 and 2016, respectively.
Professor Han is a Foreign Member of the Academia Europaea (The Academy of Europe). He is a Fellow of the International Federation of Automatic Control (FIFAC), a Fellow of the Institute of Electrical and Electronics Engineers (FIEEE), a Fellow of the Asian Control Association (FACA), an Honorary Fellow of the Institution of Engineers Australia (HonFIEAust), and a Fellow of the Chinese Association of Automation (FCAA). He is a Highly Cited Researcher in both Engineering and Computer Science (Clarivate). He has served as an AdCom Member of IEEE Industrial Electronics Society (IES), a Member of IEEE IES Fellows Committee, a Member of IEEE IES Publications Committee, Chair of IEEE IES Technical Committee on Network-Based Control Systems and Applications, and the Co-Editor-in-Chief of IEEE Transactions on Industrial Informatics. He is currently the President-Elect, an Executive Board Member, a Steering Committee Member of the Asian Control Association (ACA), and the Vice-President of the Chinese Association of Automation (CAA). He is currently the Editor-in-Chief of IEEE/CAA Journal of Automatica Sinica.

Professor Javier Gozalvez, IEEE Fellow
Universidad Miguel Hernández de Elche, Spain
Talk: V2X Connectivity and Data: Driving the Future of Connected and Automated Mobility
Abstract:
Mobility is undergoing a profound transformation toward a connected, automated, and intelligence-driven paradigm, where connectivity, data, and AI serve as fundamental enablers of safer, more efficient, and more sustainable transportation systems. This keynote explores how Vehicle-to-Everything (V2X) communications are accelerating this evolution, highlighting their role in enhancing active safety, enabling software-defined mobility, and supporting advanced connected and automated mobility services such as cooperative perception and cooperative driving. The talk examines the opportunities and challenges associated with harnessing multi-mode V2X connectivity and data to realize the full potential of future AI-driven mobility systems. Particular attention is given to ensuring resilience to data-related challenges and to the growing importance of data relevance for both autonomous driving functions and V2X communications. Building on these considerations, the keynote finally discusses how relevance-aware semantic and task-oriented communication paradigms can improve the efficiency, scalability, and robustness of future connected and automated mobility systems.
Bio:
Javier Gozalvez is Full Professor and Head of the Networked Systems laboratory at the University Miguel Hernández of Elche (UMH) in Spain. He is an IEEE Fellow for his contributions to vehicular communications and networks and a Fellow of the AAIS. He received an electronics engineering degree from the Engineering School ENSEIRB (Bordeaux, France) - now ENSEIRB-MATMECA - and a PhD in mobile communications from the University of Strathclyde, Glasgow, U.K. At UMH, he leads research activities in the areas of vehicular networks, connected and automated driving, 6G networks, and industrial wireless networks. He is a member of the Board of Governors of the IEEE Vehicular Technology Society. He served as President of the IEEE Vehicular Technology Society (2016-2017), Editor in Chief of the IEEE Vehicular Technology Magazine (2018-2024), IEEE Distinguished Lecturer and IEEE Distinguished Speaker for the IEEE Vehicular Technology Society. He is an expert evaluator for the European Commission and multiple national agencies.

Professor Zhihong Man
Swinburne University of Technology, Australia
Talk: The Design of Adaptive Control Based on Frame Theory and Attention Mechanism
Abstract:
In this talk, how frame theory and attention mechanisms are used for the design of adaptive control algorithms for single-input and single output (SISO) systems is discussed in detail. It is seen that, unlike the conventional Lyapunov-based adaptive control, both the stored past regressors and errors are used to construct a redundant frame, a frame-attention composite learning term can then be designed and added to parameter updated law. The role of the frame is to ensure that the stored historical data provides a stable and non-degenerate representation of the parameter-learning space, while the attention mechanism is capable of dynamically selecting the most informative directions of this frame. The frame-and-attention adaptive law preserves the classical Lyapunov cancellation structure and adds an attention-weighted composite learning term for improving parameter convergence and robustness against uncertain dynamics. At the end of this talk, a theorem on Lyapunov stability and parameter convergence with attention weighted frame operator is derived to formulate the new research direction on frame-attention based adaptive control.
Bio:
Zhihong received his B.E. degree from Shanghai Jiaotong University, China, in 1982, M.Sc. degree from Chinese Academy of Sciences in 1987, and PhD degree from the University of Melbourne, Australia, in 1994. From 2002 to 2007, he was the Associate Professor of Computer Engineering at Nanyang Technological University, Singapore. From 2007 to 2008, he was with Monash University Sunway Campus, served as the Professor and Head of Electrical and Computer Systems Engineering and the Chair of Monash Sunway Campus Research Committee. Zhihong is currently the Professor of Robotics and Mechatronics in the School of Engineering at Swinburne University of Technology, Melbourne, Australia.
Zhihong’s research interests are in sliding mode control, robotics, neural networks-based machine learning, vehicle dynamics & control, and fault diagnosis of aircraft engines. He has published more than 300 research papers in referred international journals and conferences proceedings. His research results have been widely cited by researchers from more than 40 different countries. Since 1994, Zhihong has been actively serving engineering societies as the general chair, program chair, track chair, session chair, and the international advisory committee and technical committees of many international conferences in control system, robotics, signal processing, neural networks and industrial electronics.
In addition, Zhihong received the Nanyang Technological University Best Teacher Award in 2004 and the Most Popular Lecturer in the School of Computer Engineering at Nanyang Technological University Singapore from 2002 to 2007, respectively.